Education & researchIn production🇺🇸 United States ・ 2024
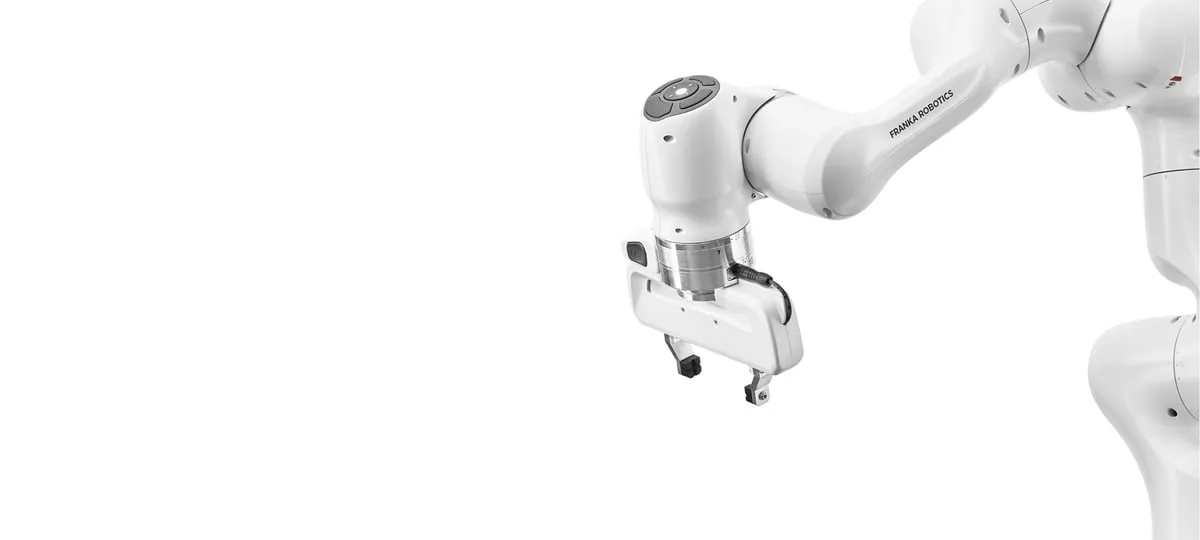
Used to collect the large-scale DROID robot dataset
DROID, a multi-institution real-world manipulation dataset, was collected on a common Franka arm platform across homes, offices and other settings, and has become a standard resource for foundation-model research.